Paper:
Electropermanent Magnet Modular Boa (EMB): Reconfigurable Snake Robot with Magnetic Wall Interaction

Snake robots possess high mobility by leveraging their redundant degrees of freedom. However, it is challenging to optimize the degrees of freedom of conventional snake robots with fixed configurations for unknown environments and it is particularly difficult to maintain their operation by detaching failed joints. To enhance the environmental adaptability and fault tolerance of snake robots, in this study, we developed a modular snake robot capable of reconfiguring its degrees of freedom according to the situation. In our previous systems, even though the mechanical coupling mechanisms achieved robust connections, the systems were structurally complex at their interfaces. In contrast, even though magnetic coupling mechanisms resulted in simpler designs, the systems were susceptible to strong vibrations and shear loads during locomotion, which made it challenging to maintain stable electrical connections. To address these challenges, we developed the electropermanent magnet modular boa (EMB) in this study, which was a modular snake robot featuring hybrid connectors that balanced strong attraction forces via electropermanent magnet with mechanical support for shear loads through passive reinforcement pins. By ensuring the precise alignment of the reinforcement pins as positioning guides, we achieved simultaneous robust inter module coupling and electrical connectivity within a lightweight and simple structure. Furthermore, a unique feature of our hybrid connector is its dual functionality, where it can also be adapted for attachment to ferromagnetic surfaces, enabling both locomotion on ferromagnetic surfaces and module coupling with a single mechanism. We demonstrated the effectiveness of the physical EMB prototype based on characteristic evaluation of the standalone connector and locomotion experiments.
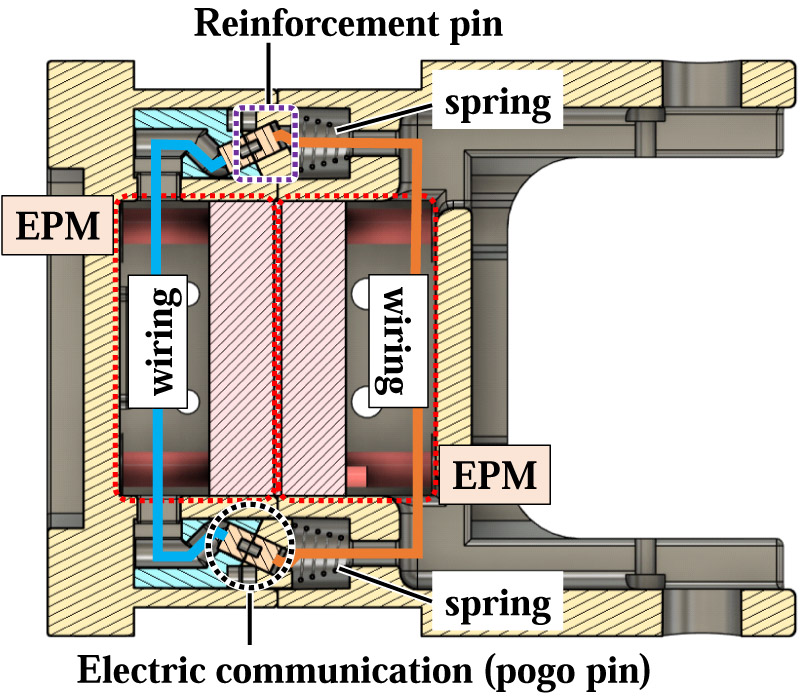
Details of the passive rod-lock mechanism and electrical contacts
This article is published under a Creative Commons Attribution-NoDerivatives 4.0 Internationa License.