Paper:
MSMS: Multiplexing Sensors and Maps System for Robust Localization by Leveraging Effective Sensors and Maps
Takumi Suzuki, Yuki Funabora
 , and Shinji Doki
Nagoya University
Furo-cho, Chikusa-ku, Nagoya, Aichi 464-8603, Japan

Because autonomous mobile robots require pose information for navigation, localization is crucial. Localization estimates a robot’s pose by matching currently observed features with a pre-constructed map. However, each sensor has environments in which the localization accuracy deteriorates owing to the environmental dependency of the sensors, making robust localization with a single sensor difficult. Sensor multiplexing methods have been proposed to address this issue. In addition, condition changes can alter observed environmental features, causing mismatches between current observations and the map because of the condition dependency of maps. This makes robust localization in such environments difficult. Map multiplexing methods have been proposed to address this. Robust localization can be achieved against the environmental dependency of sensors by multiplexing sensors and against the condition dependency of maps by multiplexing maps. However, multiplexing using sensors or maps is insufficient to achieve robust localization against both types of dependency. Hence, in this paper, we propose a system that multiplexes both sensors and maps. Experiments using a dataset confirmed that the proposed system achieved robust localization against both types of dependency.
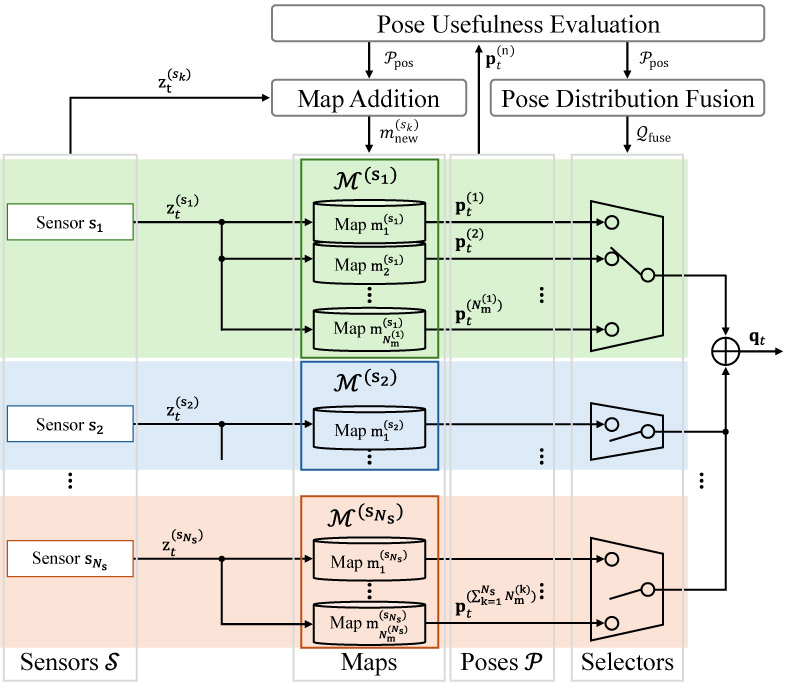
MSMS: Multiplexing sensors and maps system
- [1] J. Graeter, A. Wilczynski, and M. Lauer, “Limo: Lidar-monocular visual odometry,” 2018 IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), pp. 7872-7879, 2018. https://doi.org/10.1109/IROS.2018.8594394
- [2] S. Khan, D. Wollherr, and M. Buss, “Modeling laser intensities for simultaneous localization and mapping,” IEEE Robotics and Automation Letters, Vol.1, No.2, pp. 692-699, 2016. https://doi.org/10.1109/LRA.2016.2516592
- [3] J. Biswas and M. Veloso, “Depth camera based indoor mobile robot localization and navigation,” 2012 IEEE Int. Conf. on Robotics and Automation, pp. 1697-1702, 2012. https://doi.org/10.1109/ICRA.2012.6224766
- [4] J. A. Castellanos, J. Neira, and J. D. Tardós, “Multisensor fusion for simultaneous localization and map building,” IEEE Trans. on Robotics and Automation, Vol.17, No.6, pp. 908-914, 2001. https://doi.org/10.1109/70.976024
- [5] H. T. Niknejad, M. Seiichi, H. Long, and H. Quoc, “Multi-sensor data fusion for autonomous vehicle navigation and localization through precise map,” Int. J. of Automotive Engineering, Vol.3, No.1, pp. 19-25, 2012. https://doi.org/10.20485/jsaeijae.3.1_19
- [6] T. Shan and B. Englot, “Lego-loam: Lightweight and ground-optimized lidar odometry and mapping on variable terrain,” 2018 IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), pp. 4758-4765, 2018. https://doi.org/10.1109/IROS.2018.8594299
- [7] B. Yang and R. Yang, “Interactive particle filter with occlusion handling for multi-target tracking,” 2015 12th Int. Conf. on Fuzzy Systems and Knowledge Discovery (FSKD), pp. 1945-1949, 2015. https://doi.org/10.1109/FSKD.2015.7382246
- [8] A. Bajcsy, S. L. Herbert, D. Fridovich-Keil, J. F. Fisac, S. Deglurkar, A. D. Dragan, and C. J. Tomlin, “A scalable framework for real-time multi-robot, multi-human collision avoidance,” 2019 Int. Conf. on Robotics and Automation (ICRA), pp. 936-943, 2019. https://doi.org/10.1109/ICRA.2019.8794457
- [9] H. Liu, H. Huang, S.-K. Yeung, and M. Liu, “360ST-Mapping: An Online Semantics-Guided Topological Mapping Module for Omnidirectional Visual SLAM,” 2022 IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), pp. 802-807, 2022. https://doi.org/10.1109/IROS47612.2022.9982142
- [10] J. Wang, B. Tian, R. Zhang, and L. Chen, “ULSM: Underground Localization and Semantic Mapping with Salient Region Loop Closure under Perceptually-Degraded Environment,” 2022 IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), pp. 1320-1327, 2022. https://doi.org/10.1109/IROS47612.2022.9982170
- [11] R. Long, C. Rauch, T. Zhang, V. Ivan, T. L. Lam, and S. Vijayakumar, “RGB-D SLAM in Indoor Planar Environments with Multiple Large Dynamic Objects,” IEEE Robotics and Automation Letters, Vol.7, No.3, pp. 8209-8216, 2022. https://doi.org/10.1109/LRA.2022.3186091
- [12] Y. Wang, K. Xu, Y. Tian, and X. Ding, “DRG-SLAM: A Semantic RGB-D SLAM Using Geometric Features for Indoor Dynamic Scene,” 2022 IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), pp. 1352-1359, 2022. https://doi.org/10.1109/IROS47612.2022.9981238
- [13] K. Gunji, K. Ohno, S. Kojima, R. Bezerra, Y. Okada, M. Konyo, and S. Tadokoro, “LayoutSLAM: Object Layout based Simultaneous Localization and Mapping for Reducing Object Map Distortion,” 2022 IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), pp. 2825-2832, 2022. https://doi.org/10.1109/IROS47612.2022.9981492
- [14] A. Papadimitriou, I. Kleitsiotis, I. Kostavelis, I. Mariolis, D. Giakoumis, S. Likothanassis, and D. Tzovaras, “Loop Closure Detection and SLAM in Vineyards with Deep Semantic Cues,” 2022 Int. Conf. on Robotics and Automation (ICRA), pp. 2251-2258, 2022. https://doi.org/10.1109/ICRA46639.2022.9812419
- [15] J. Liu, K. Chen, R. Liu, Y. Yang, Z. Wang, and J. Zhang, “Robust and Accurate Multi-Agent SLAM with Efficient Communication for Smart Mobiles,” 2022 Int. Conf. on Robotics and Automation (ICRA), pp. 2782-2788, 2022. https://doi.org/10.1109/ICRA46639.2022.9812366
- [16] Y. Huang, T. Shan, F. Chen, and B. Englot, “DiSCo-SLAM: Distributed Scan Context-Enabled Multi-Robot LiDAR SLAM with Two-Stage Global-Local Graph Optimization,” IEEE Robotics and Automation Letters, Vol.7, No.2, pp. 1150-1157, 2022. https://doi.org/10.1109/LRA.2021.3138156
- [17] M. Frosi and M. Matteucci, “ART-SLAM: Accurate Real-Time 6DoF LiDAR SLAM,” IEEE Robotics and Automation Letters, Vol.7, No.2, pp. 2692-2699, 2022. https://doi.org/10.1109/LRA.2022.3144795
- [18] Z. Liao, Y. Hu, J. Zhang, X. Qi, X. Zhang, and W. Wang, “SO-SLAM: Semantic Object SLAM with Scale Proportional and Symmetrical Texture Constraints,” IEEE Robotics and Automation Letters, Vol.7, No.2, pp. 4008-4015, 2022. https://doi.org/10.1109/LRA.2022.3148465
- [19] A. Zhang and M. M. Atia, “Comparison of 2D localization using radar and LiDAR in long corridors,” 2020 IEEE SENSORS, 2020. https://doi.org/10.1109/SENSORS47125.2020.9278684
- [20] X. Deng, Z. Zhang, A. Sintov, J. Huang, and T. Bretl, “Feature-constrained Active Visual SLAM for Mobile Robot Navigation,” 2018 IEEE Int. Conf. on Robotics and Automation (ICRA), pp. 7233-7238, 2018. https://doi.org/10.1109/ICRA.2018.8460721
- [21] G. Nützi, S. Weiss, D. Scaramuzza, and R. Siegwart, “Fusion of IMU and vision for absolute scale estimation in monocular SLAM,” J. of Intelligent & Robotic Systems, Vol.61, No.1, pp. 287-299, 2011. https://doi.org/10.1007/s10846-010-9490-z
- [22] E. López, R. Barea, A. Gómez, Á. Saltos, L. M. Bergasa, E. J. Molinos, and A. Nemra, “Indoor SLAM for micro aerial vehicles using visual and laser sensor fusion,” Robot 2015: Second Iberian Robotics Conf. pp. 531-542, 2015. https://doi.org/10.1007/978-3-319-27146-0_41
- [23] P. Carrasco, F. Cuesta, R. Caballero, F. J. Perez-Grau, and A. Viguria, “Multi-sensor fusion for aerial robots in industrial GNSS-denied environments,” Applied Sciences, Vol.11, No.9, Article No.3921, 2021. https://doi.org/10.3390/app11093921
- [24] Y. Wang and X. Li, “The IMU/UWB fusion positioning algorithm based on a particle filter,” ISPRS Int. J. of Geo-Information, Vol.6, No.8, Article No.235, 2017. https://doi.org/10.3390/ijgi6080235
- [25] R. Mascaro, L. Teixeira, T. Hinzmann, R. Siegwart, and M. Chli, “GOMSF: Graph-optimization based multi-sensor fusion for robust UAV pose estimation,” 2018 IEEE Int. Conf. on Robotics and Automation (ICRA), pp. 1421-1428, 2018. https://doi.org/10.1109/ICRA.2018.8460193
- [26] Y. Jia, H. Luo, F. Zhao, G. Jiang, Y. Li, J. Yan, Z. Jiang, and Z. Wang, “Lvio-fusion: A self-adaptive multi-sensor fusion SLAM framework using actor-critic method,” 2021 IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), pp. 286-293, 2021. https://doi.org/10.1109/IROS51168.2021.9635905
- [27] N. Ohashi, Y. Funabora, S. Doki, and K. Doki, “Multisensor robust localization in various environment with correlation checking test,” ROBOMECH J., Vol.8, Article No.3, 2021. https://doi.org/10.1186/s40648-021-00190-9
- [28] T. Suzuki, Y. Funabora, S. Doki, K. Doki, and M. Yamazumi, “DSFS: Dynamic Sensor Fusion System for Robust Localization with Diverse Sensing Information,” J. Robot. Mechatron., Vol.37, No.5, pp. 1127-1136, 2025. https://doi.org/10.20965/jrm.2025.p1127
- [29] J. Lee, M. Ohata, H. Itoh, and E. Morimoto, “LiDAR–Camera Fusion for 3D Fruit Counting and Density Mapping in Horizontal Trellis Orchards,” J. Robot. Mechatron., Vol.38, No.2, pp. 449-459, 2026. https://doi.org/10.20965/jrm.2026.p0449
- [30] S. A. Rahok, R. Onozuka, H. Oneda, K. Inoue, Y. Tokoi, A. Tanaka, and K. Ozaki, “Global and Local Localizations Using an Environmental Magnetic Field and a Scan Matching Method,” J. Robot. Mechatron., Vol.37, No.6, pp. 1365-1373, 2025. https://doi.org/10.20965/jrm.2025.p1365
- [31] D. Avots, E. Lim, R. Thibaux, and S. Thrun, “A probabilistic technique for simultaneous localization and door state estimation with mobile robots in dynamic environments,” IEEE/RSJ Int. Conf. on Intelligent Robots and Systems, pp. 521-526, 2002. https://doi.org/10.1109/IRDS.2002.1041443
- [32] G. Pascoe, W. Maddern, M. Tanner, P. Piniés, and P. Newman, “NID-SLAM: Robust monocular SLAM using normalised information distance,” Proc. of the IEEE Conf. on Computer Vision and Pattern Recognition, pp. 1435-1444, 2017. https://doi.org/10.1109/CVPR.2017.158
- [33] P. Biber and T. Duckett, “Experimental analysis of sample-based maps for long-term SLAM,” The Int. J. of Robotics Research, Vol.28, No.1, pp. 20-33, 2009. https://doi.org/10.1177/0278364908096286
- [34] P. Biber and T. Duckett, “Dynamic maps for long-term operation of mobile service robots,” Proc. of Robotics: Science and Systems (RSS), pp. 17-24, 2005. https://doi.org/10.15607/RSS.2005.I.003
- [35] C. Stachniss and W. Burgard, “Mobile robot mapping and localization in non-static environments,” Proc. of the 20th National Conf. on Artificial Intelligence (AAAI’05) pp. 1324-1329, 2005.
- [36] M. Labbé and F. Michaud, “Multi-session visual SLAM for illumination-invariant re-localization in indoor environments,” Frontiers in Robotics and AI, Vol.9, Article No.801886, 2022. https://doi.org/10.3389/frobt.2022.801886
- [37] C. Linegar, W. Churchill, and P. Newman, “Work smart, not hard: Recalling relevant experiences for vast-scale but time-constrained localisation,” 2015 IEEE Int. Conf. on Robotics and Automation (ICRA), pp. 90-97, 2015. https://doi.org/10.1109/ICRA.2015.7138985
- [38] T. Morris, F. Dayoub, P. Corke, G. Wyeth, and B. Upcroft, “Multiple map hypotheses for planning and navigating in non-stationary environments,” 2014 IEEE Int. Conf. on Robotics and Automation (ICRA), pp. 2765-2770, 2014. https://doi.org/10.1109/ICRA.2014.6907255
- [39] T. Suzuki, Y. Funabora, S. Doki, and K. Doki, “Robust Localization using Map Selection from Multiple Maps Based on the Relative Pose Difference of Map and Interoceptive Sensor,” 2026 IEEE/SICE Int. Symposium on System Integrations (SII2026), 2026. https://doi.org/10.1109/SII64115.2026.11404656
- [40] N. Trekel, T. Guadagnino, T. Läbe, L. Wiesmann, P. Aguiar, J. Behley, and C. Stachniss, “Benchmark for Evaluating Long-Term Localization in Indoor Environments Under Substantial Static and Dynamic Scene Changes,” Proc. of the IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), 2025. https://doi.org/10.1109/IROS60139.2025.11246416
- [41] W. Hess, D. Kohler, H. Rapp, and D. Andor, “Real-time loop closure in 2D LIDAR SLAM,” 2016 IEEE Int. Conf. on Robotics and Automation (ICRA), pp. 1271-1278, 2016. https://doi.org/10.1109/ICRA.2016.7487258
- [42] R. Mur-Artal and J. D. Tardós, “ORB-SLAM2: An Open-Source SLAM System for Monocular, Stereo, and RGB-D Cameras,” IEEE Trans. on Robotics, Vol.33, No.5, pp. 1255-1262, 2017. https://doi.org/10.1109/TRO.2017.2705103
This article is published under a Creative Commons Attribution-NoDerivatives 4.0 Internationa License.